Environment Sensor (LoRaWAN)
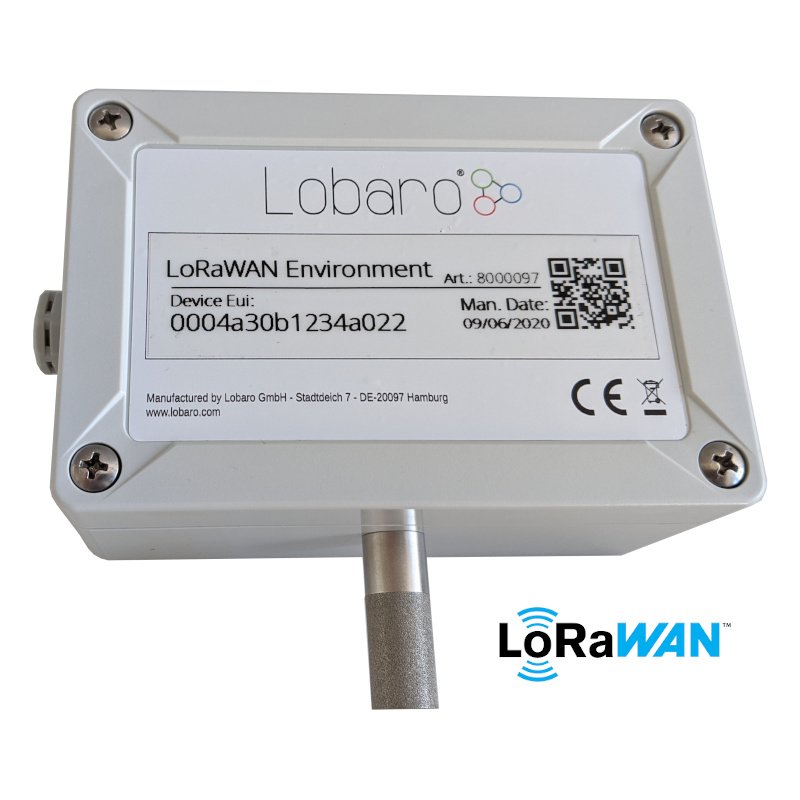
Target Measurement and Purpose
High-precision measurement of temperature, humidity, and pressure using the Bosch BME680 environmental sensor.
Configuration
For configuration of the LoRaWAN parameters, refer to the LoRaWAN configuration article.
| Name | Description | Example value |
|---|---|---|
MeasureCron | Cron expression defining when a measurement is taken. | 0 0/15 * * * * for every 15 minutes |
See also our Introduction to CRON expressions.
Firmware update notifications are described on the Firmware & Updates page.
Payload
Example payloads for each port:
Status Message (Port 1)
Payload: no example available yet.
Decoded:
{
  "temp": 20.4,
  "vBat": 3.0,
  "version": "v0.0.1"
}
Data Message (Port 2)
Structure:
| Name | Pos | Len | Type | Description |
|---|---|---|---|---|
| timestamp | 0 | 5 | uint40 | Time of measurement, see timestamps in our LoRaWAN devices. |
| error flag | 5 | 1 | byte | 1: error, 0: success |
| humidity | 6 | 2 | uint16 BE | Humidity in 1/10 % rH |
| temperature | 8 | 2 | int16 BE | Temperature in 1/10 °C |
| pressure | 10 | 2 | uint16 BE | Pressure in 10 Pa |
Example payload: 00386d440700015400f527d1
Decoded:
{
  "error": false,
  "humidity": 34,
  "pressure": 1019.3,
  "temperature": 24.5,
  "time": 946684935000
}
Parser
JavaScript Parser
Environment Sensor payload parser
function readVersion(bytes, i) {
    if (bytes.length < 3) {
        return null;
    }
    return "v" + bytes[i] + "." + bytes[i + 1] + "." + bytes[i + 2];
}

function signed(val, bits) {
    if ((val & 1 << (bits - 1)) > 0) { // value is negative (16bit 2's complement)
        var mask = Math.pow(2, bits) - 1;
        val = (~val & mask) + 1; // invert all bits & add 1 => now positive value
        val = val * -1;
    }
    return val;
}

function uint40_BE(bytes, idx) {
    bytes = bytes.slice(idx || 0);
    return bytes[0] << 32 |
        bytes[1] << 24 | bytes[2] << 16 | bytes[3] << 8 | bytes[4] << 0;
}

function uint16_BE(bytes, idx) {
    bytes = bytes.slice(idx || 0);
    return bytes[0] << 8 | bytes[1] << 0;
}

function int40_BE(bytes, idx) {
    return signed(uint40_BE(bytes, idx), 40);
}

function int16_BE(bytes, idx) {
    return signed(uint16_BE(bytes, idx), 16);
}

function ParseStatusMessage(data) {
    var decoded = {};
    decoded.version = readVersion(data, 0);
    decoded.vBat = uint16_BE(data, 5) / 1000.0;
    decoded.temp = int16_BE(data, 3) / 10.0; // byte 8-9 (originally in 10th degree C)
    decoded.msg = "Firmware Version: " + decoded.FirmwareVersion + " Battery: " + decoded.Vbat + "V Temperature: " + decoded.Temp + "°C";
    return decoded;
}

function ParseDataMessage(data) {
    return {
        "time": int40_BE(data, 0) * 1000,
        "error": !!data[5],
        "humidity": uint16_BE(data, 6) / 10.0,
        "temperature": int16_BE(data, 8) / 10.0,
        "pressure": uint16_BE(data, 10) / 10
    };
}

// Decoder function for TTN
function Decoder(bytes, port) {
    // Decode an incoming message to an object of fields.
    var decoded;

    switch (port) {
        case 1:
            decoded = ParseStatusMessage(bytes);
            break;
        case 2:
            decoded = ParseDataMessage(bytes);
            break;
        default:
            decoded = {};
    }

    return decoded;
}

// Wrapper for Lobaro Platform
function Parse(input) {
    // Decode an incoming message to an object of fields.
    var b = bytes(atob(input.data));
    var decoded = Decoder(b, input.fPort);

    if (input.fPort == 2) {
        Device.setProperty("status.firmware", decoded.FirmwareVersion);
        Device.setProperty("status.voltage", decoded.Vbat);
        Device.setProperty("status.temperature", decoded.Temp);
    }

    return decoded;
}

// Wrapper for Loraserver / ChirpStack
function Decode(fPort, bytes) {
    return Decoder(bytes, fPort);
}

/*
// Wrapper for Digimondo niota.io
module.exports = function (payload, meta) {
    const port = meta.lora.fport;
    const buf = Buffer.from(payload, 'hex');

    return Decoder(buf, port);
};
*/